
 Motion Studio
Turn motion ideas
into usable data.
Start with text, video or motion capture.
Edit, retarget, correct and prepare for training.
Describe the action.
See it happen.
Describe the motion you want,
then preview the result.
Extract motion from a video.
Every frame
can be refined.
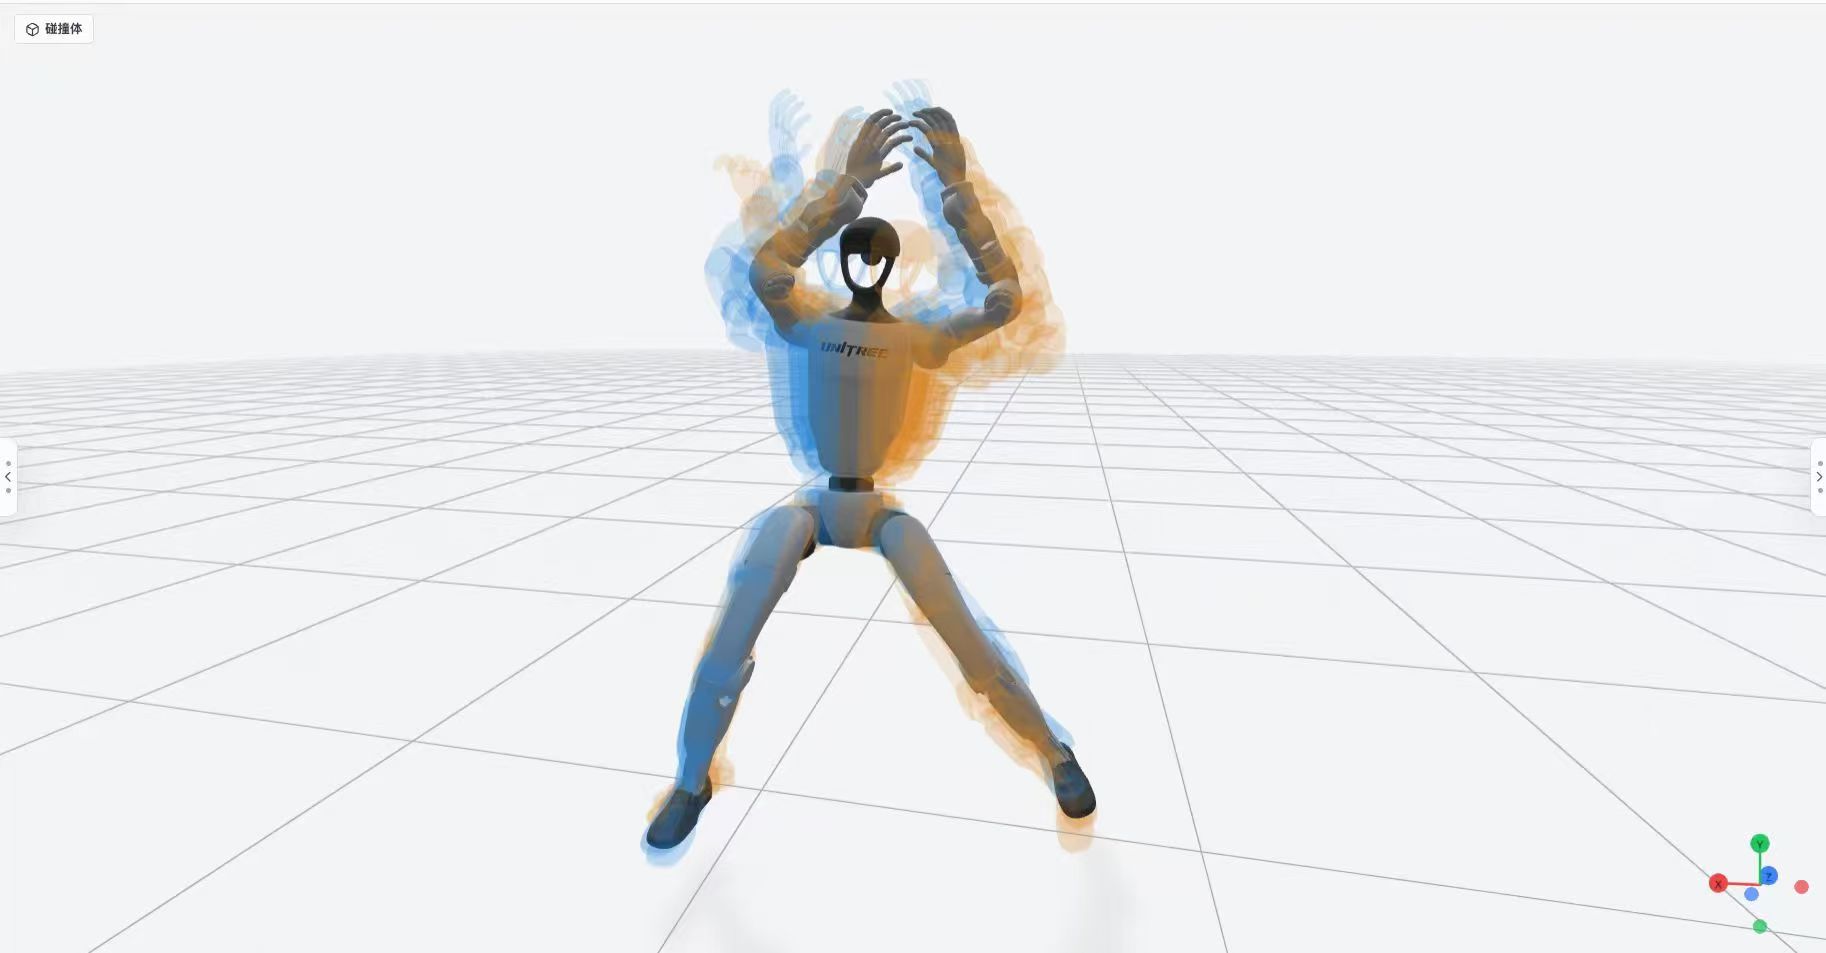
Locate clips, adjust poses and inspect changes.
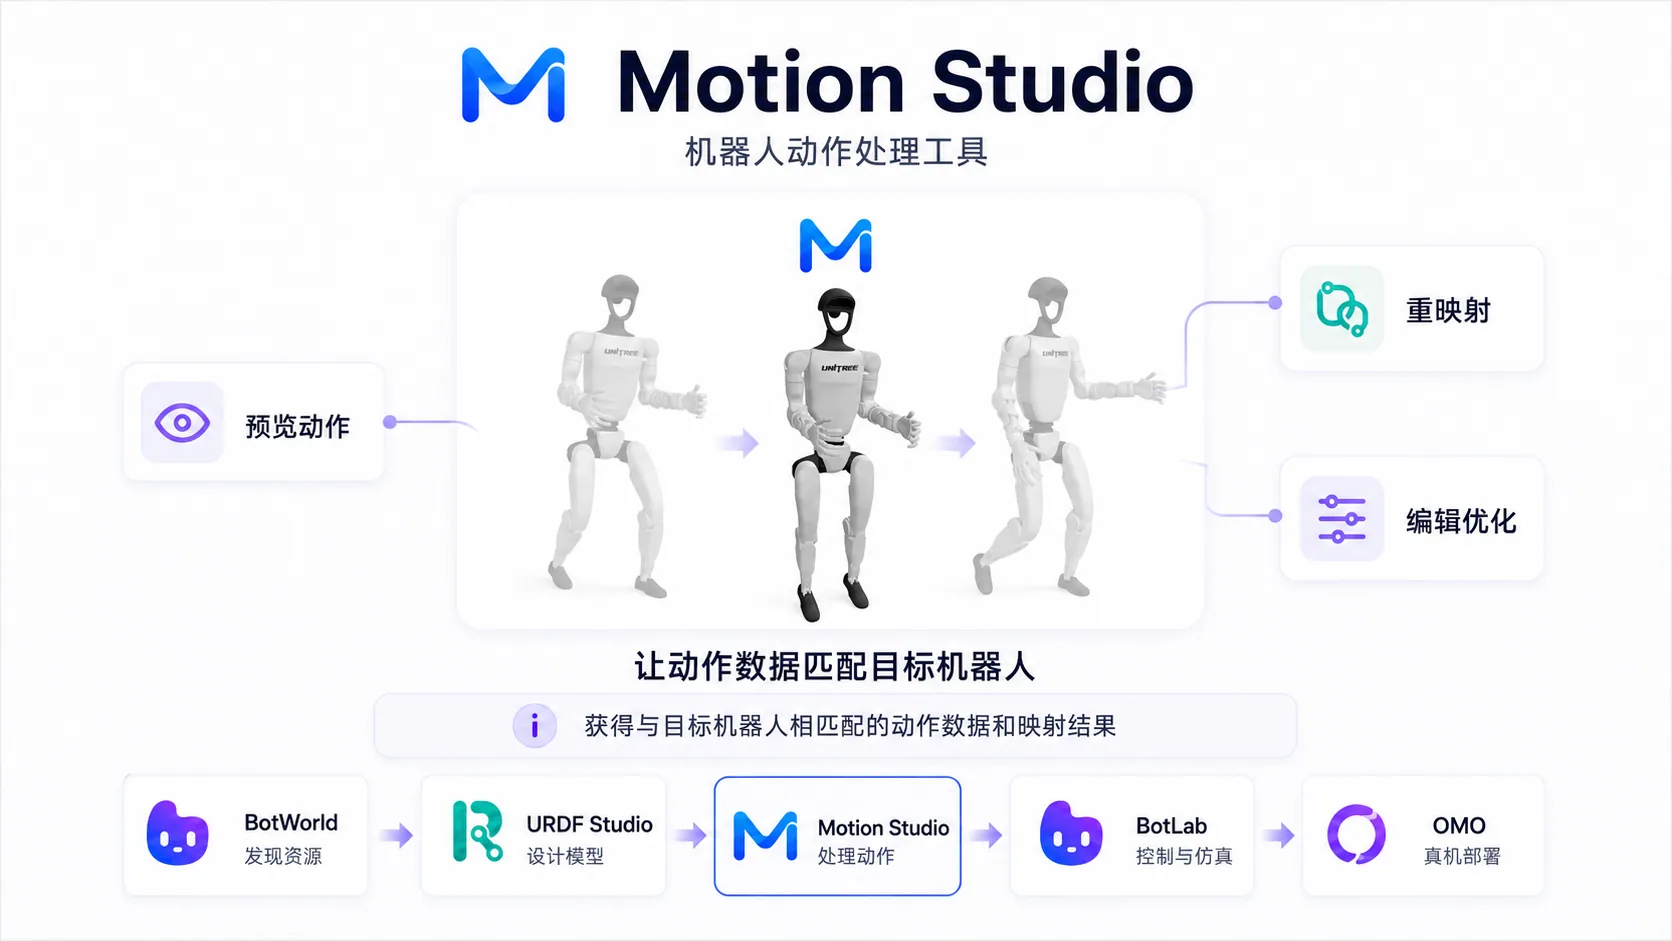
Adapt human motion
to your robot.
Align reference poses and define joint mappings.
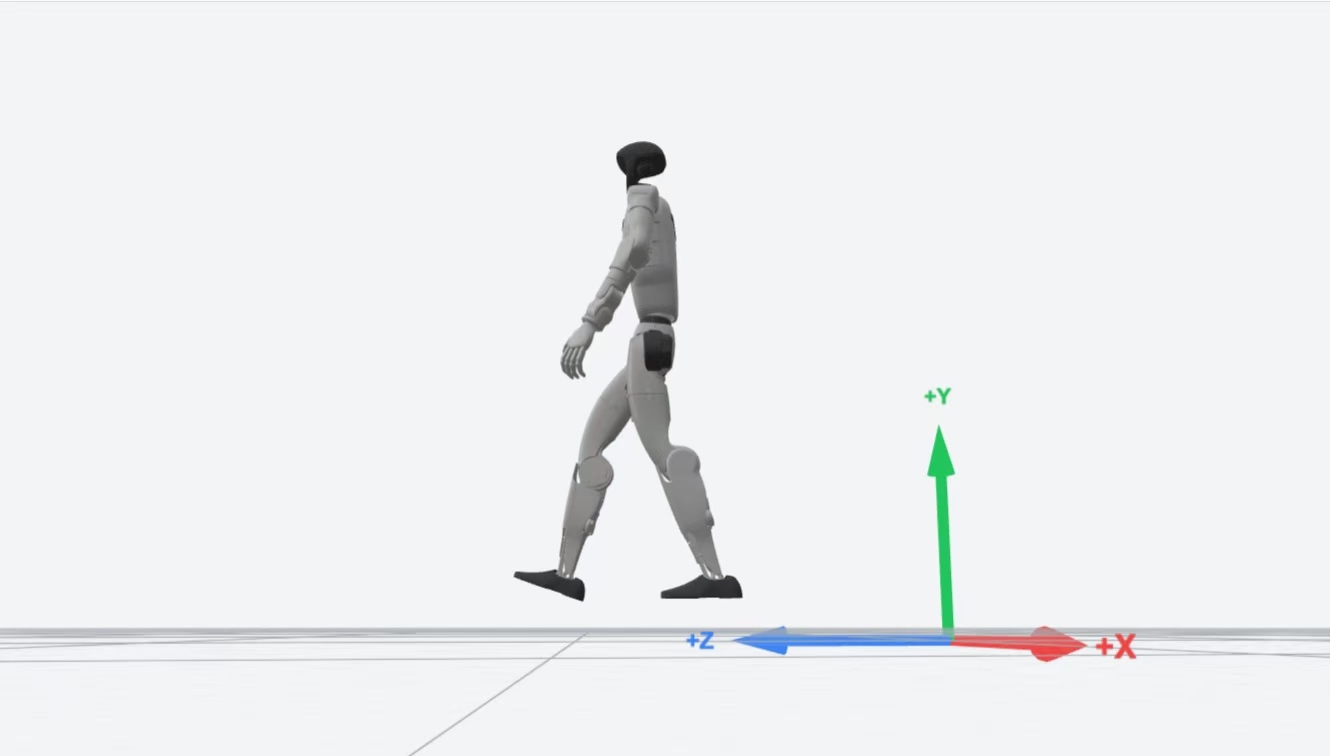
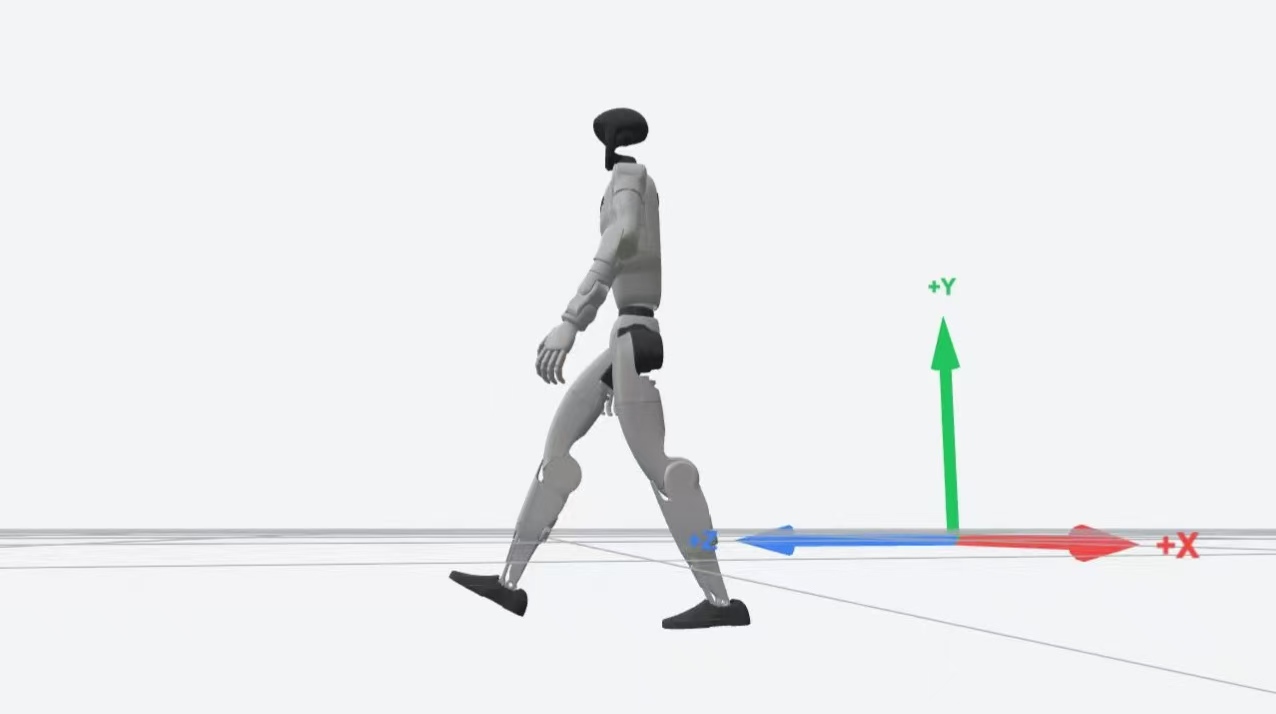
Inspect motion on the robot.
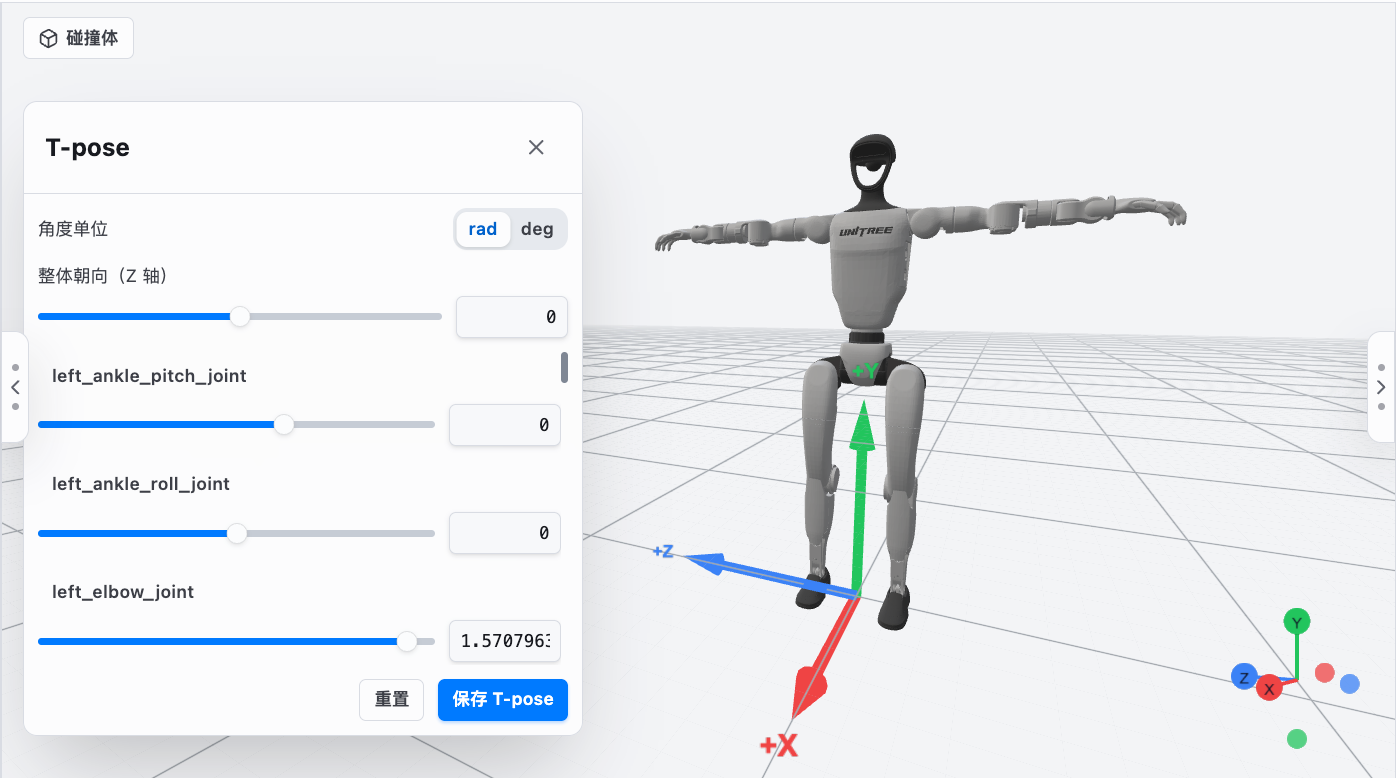
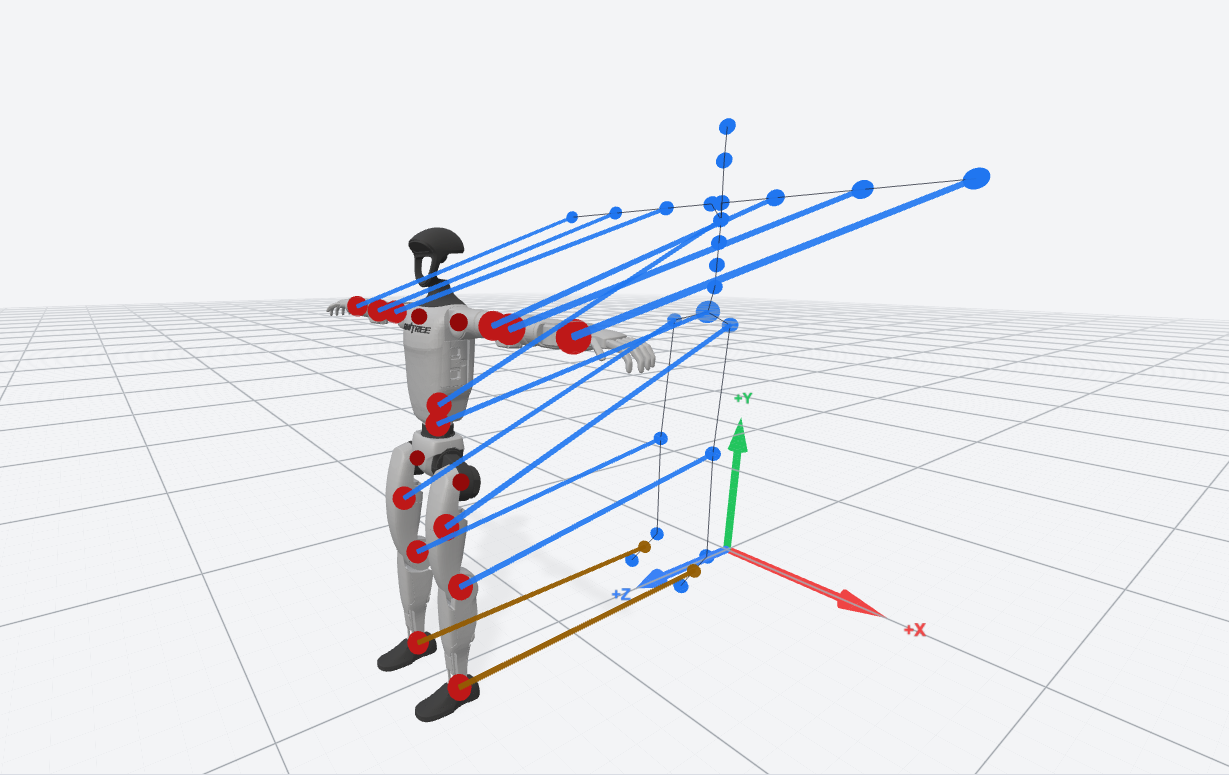
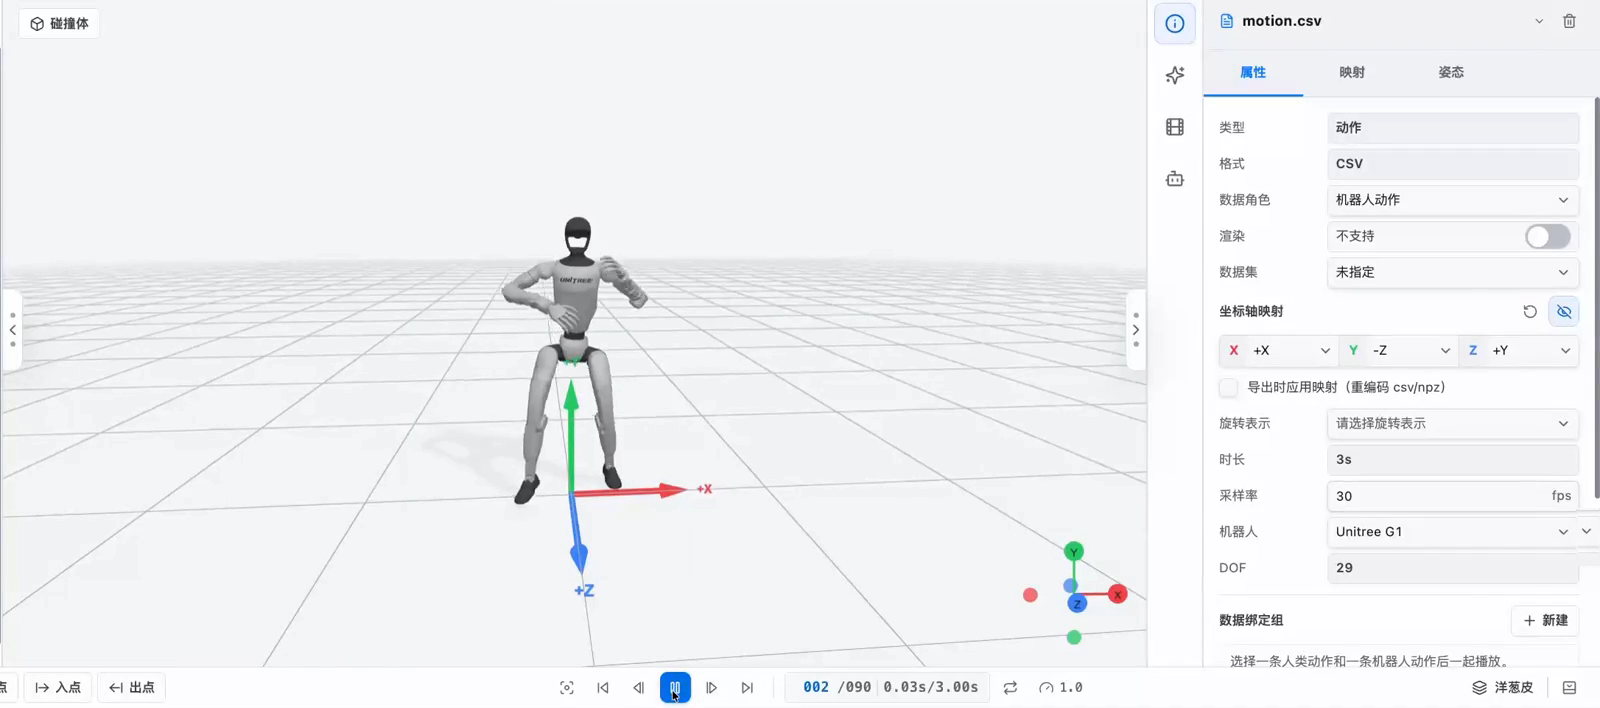
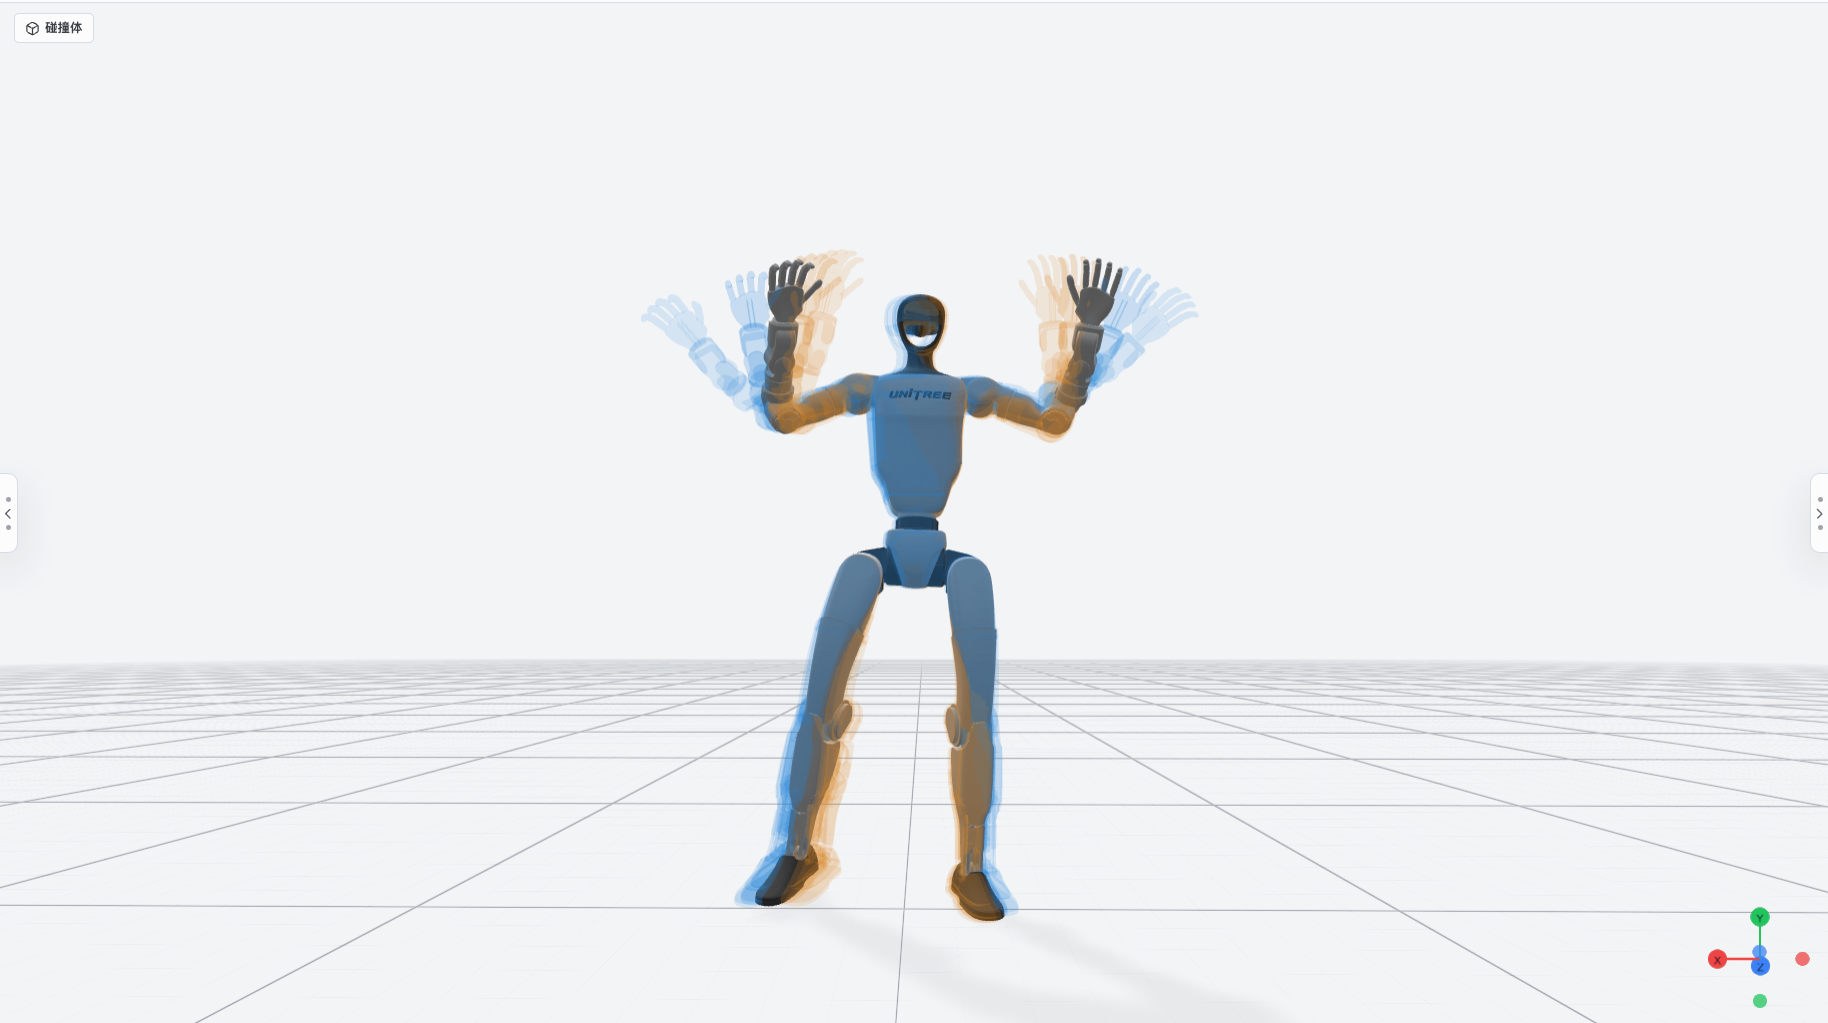
See the issue. See the improvement.
Can I continue editing existing motion data?
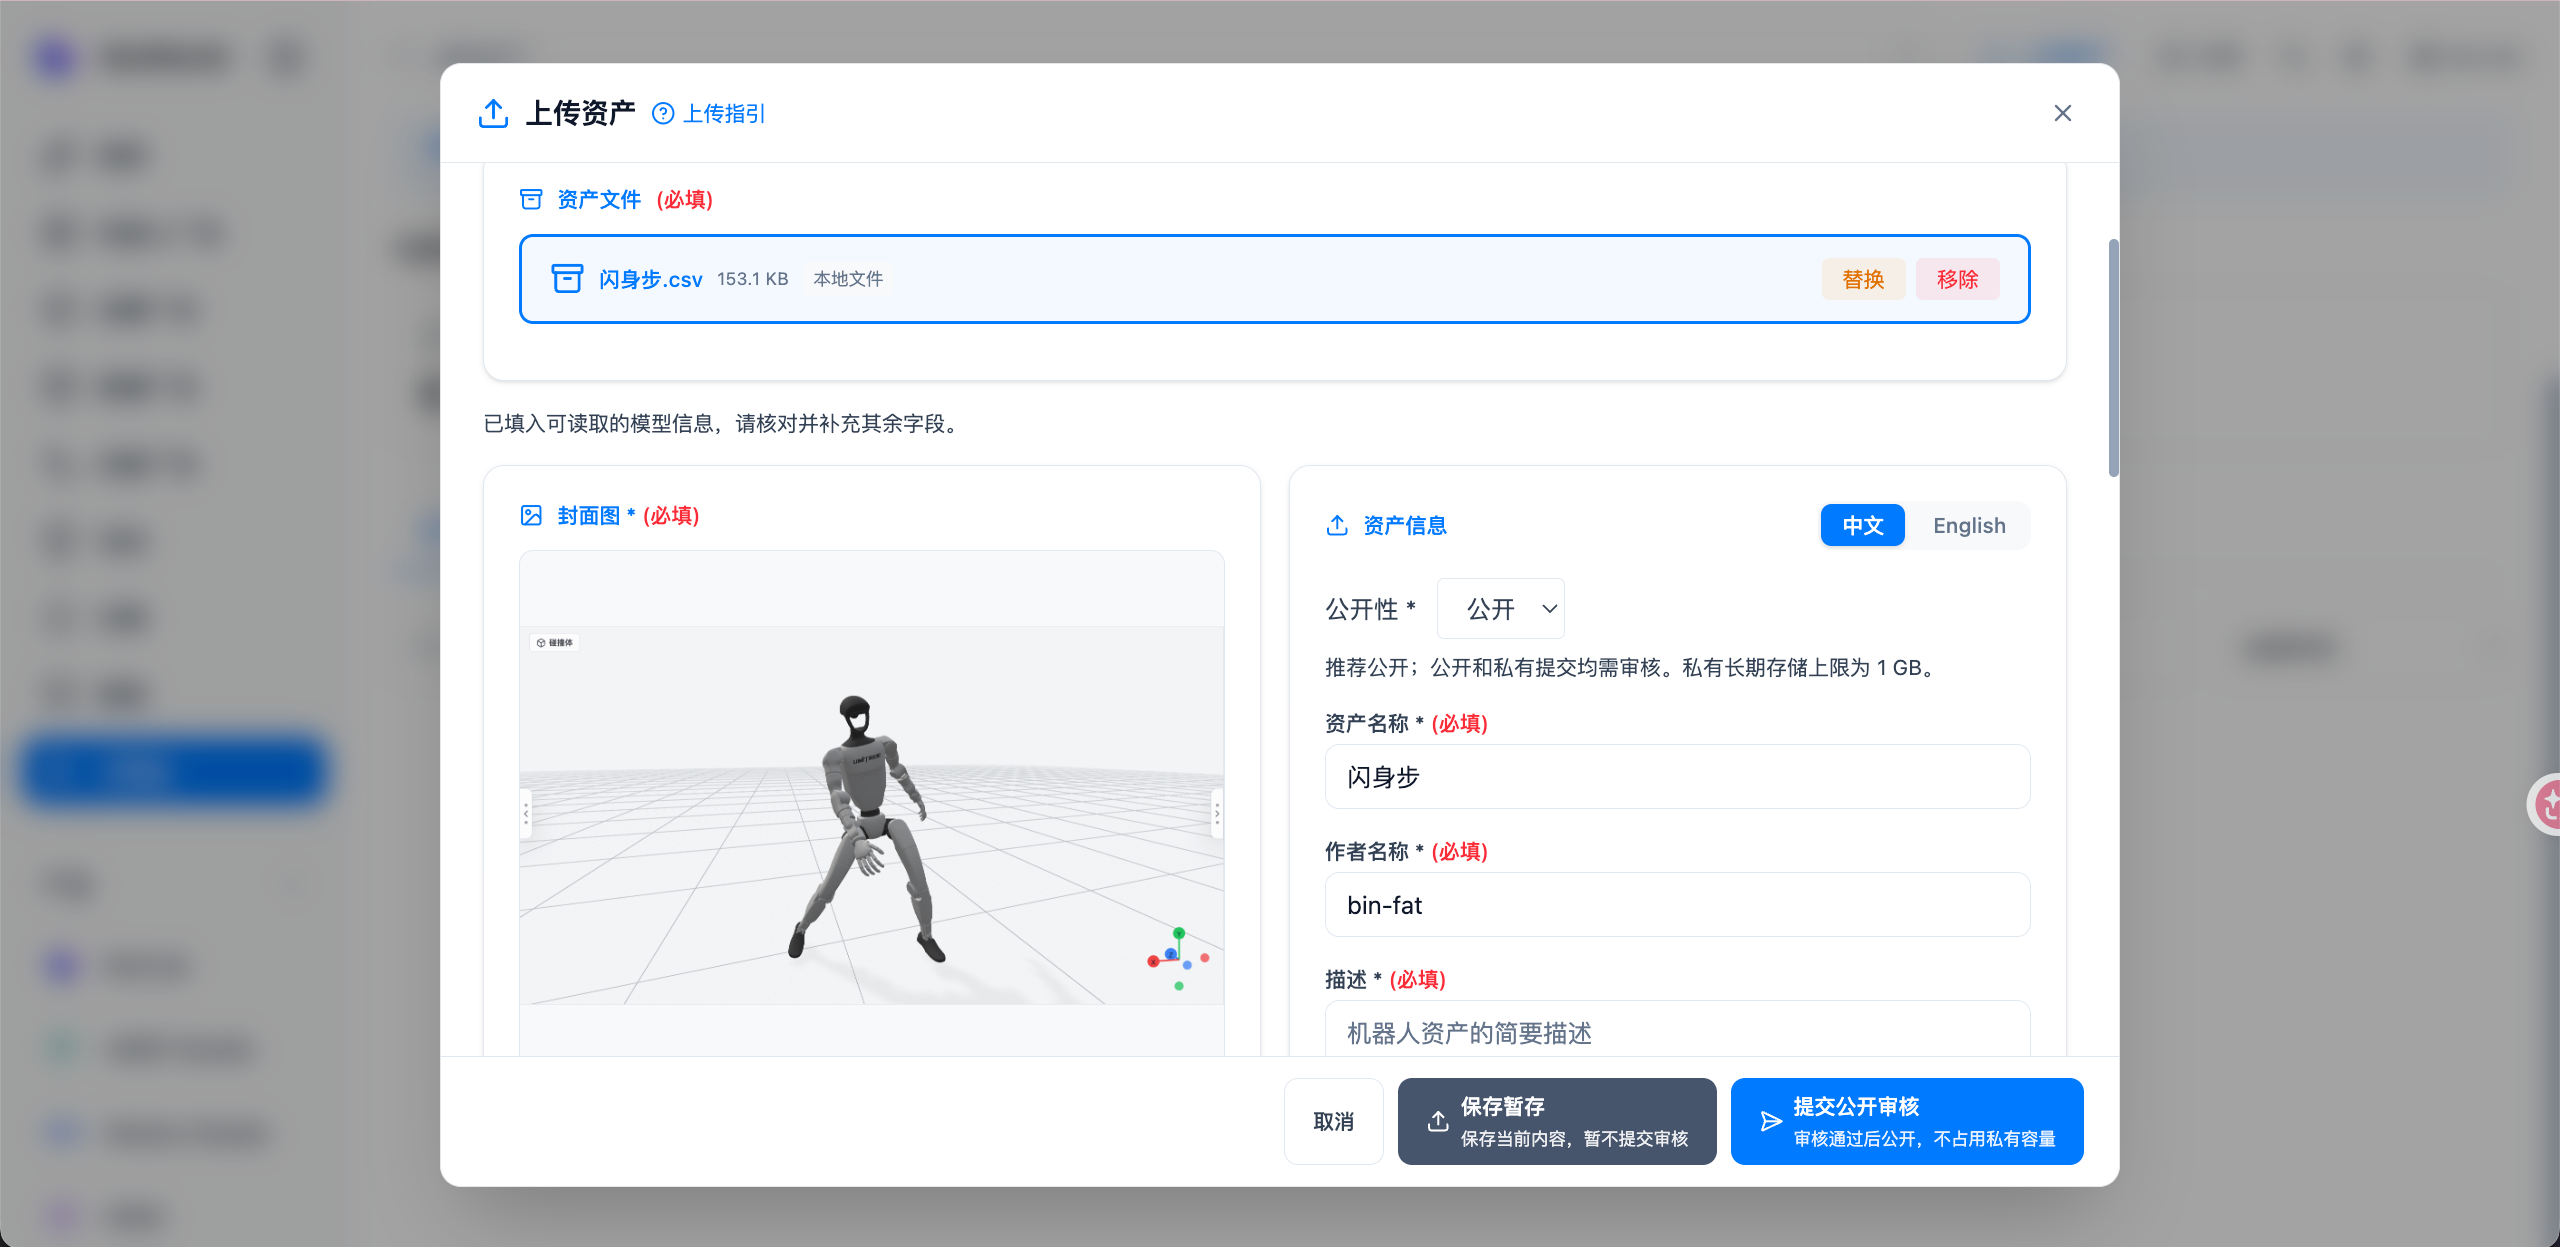
Start from an existing motion file and continue into preview, editing and robot adaptation. Consult the product documentation for supported formats.
Which features are previews?
Text-to-motion, video-to-motion and automatic optimisation include internal previews. Availability depends on the specific version.
Can retargeted motion directly control real hardware?
Retargeting provides motion data for the target robot. Execution still requires policy training, physics simulation and real-robot validation.
What information should I deliver for training?
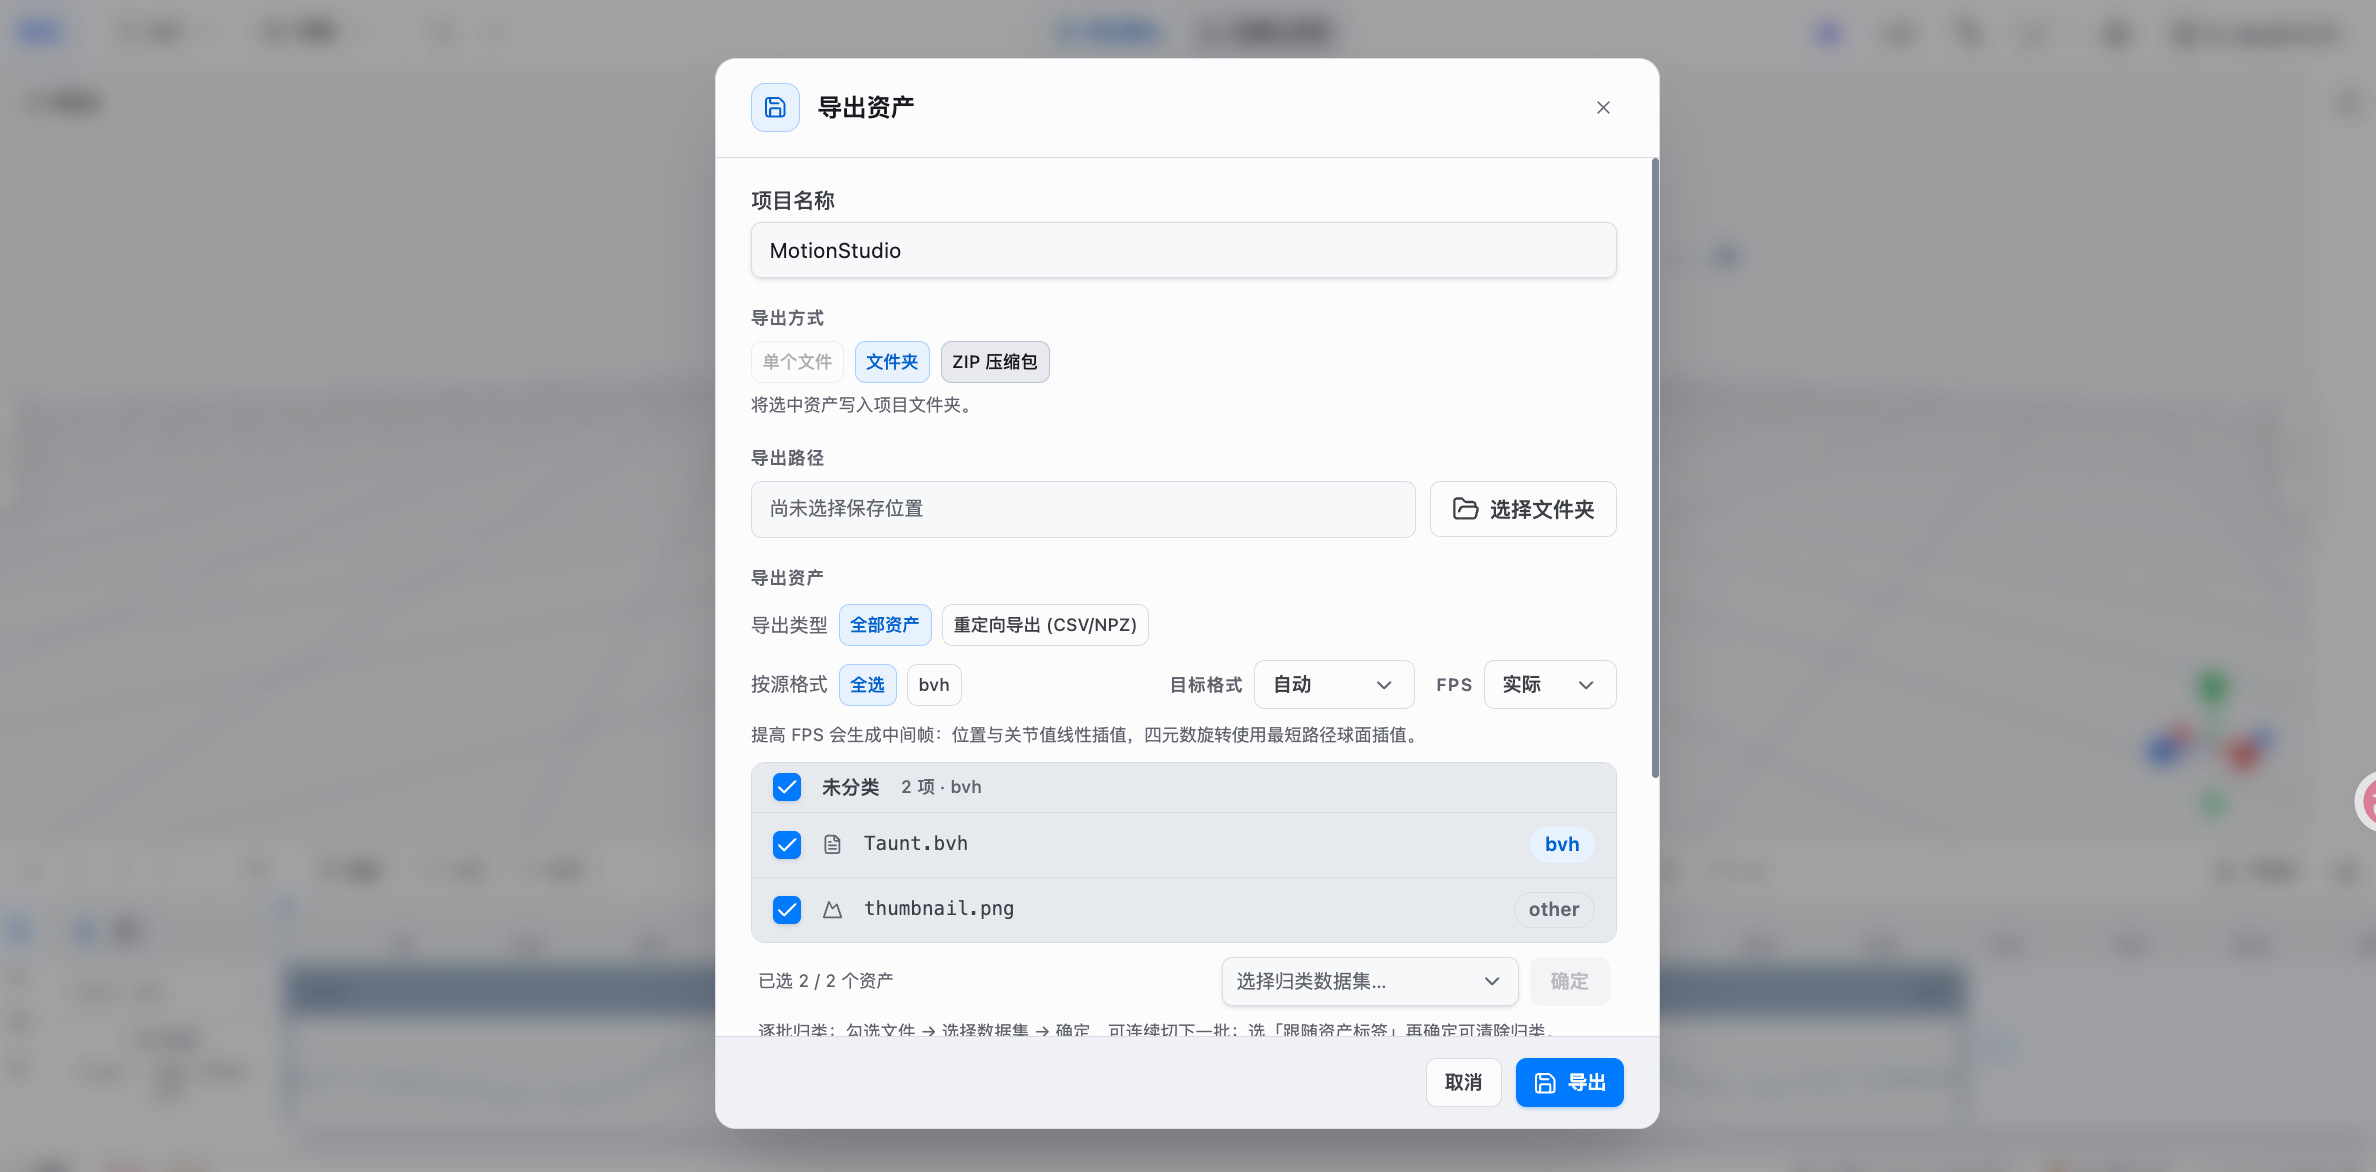
Motion data, frame rate, coordinate conventions, joint order and mapping configuration, organised for the target training method.